


Natural conversation, autonomous following, and companionship for the whole family.
$2,499
LIMITED Founder Edition
99 OF 200 UNITS LEFT
Reserve your spot to co-create the open RL platform.


01
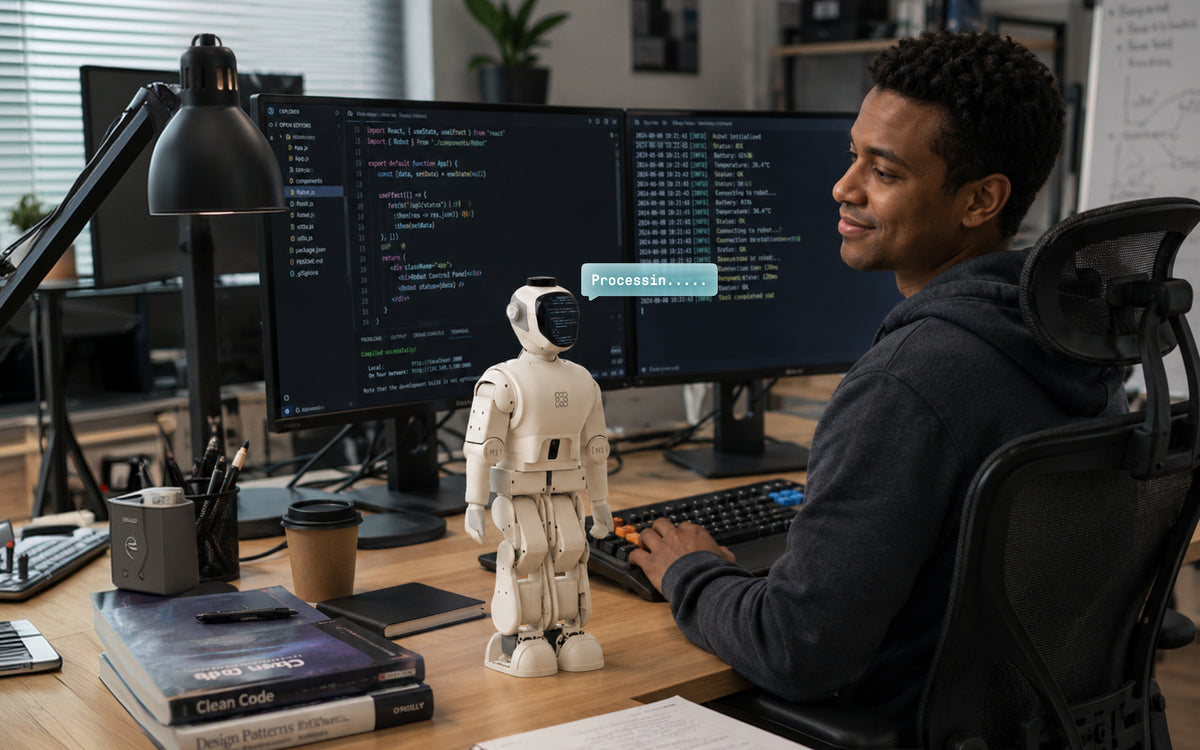
Sim-to-real policy transfer
Train locomotion and balance policies with reference workflows in Isaac Gym. Designed for PyTorch/ONNX model export and sim-to-real pipelines via the Reinforced Imitation Framework.
02
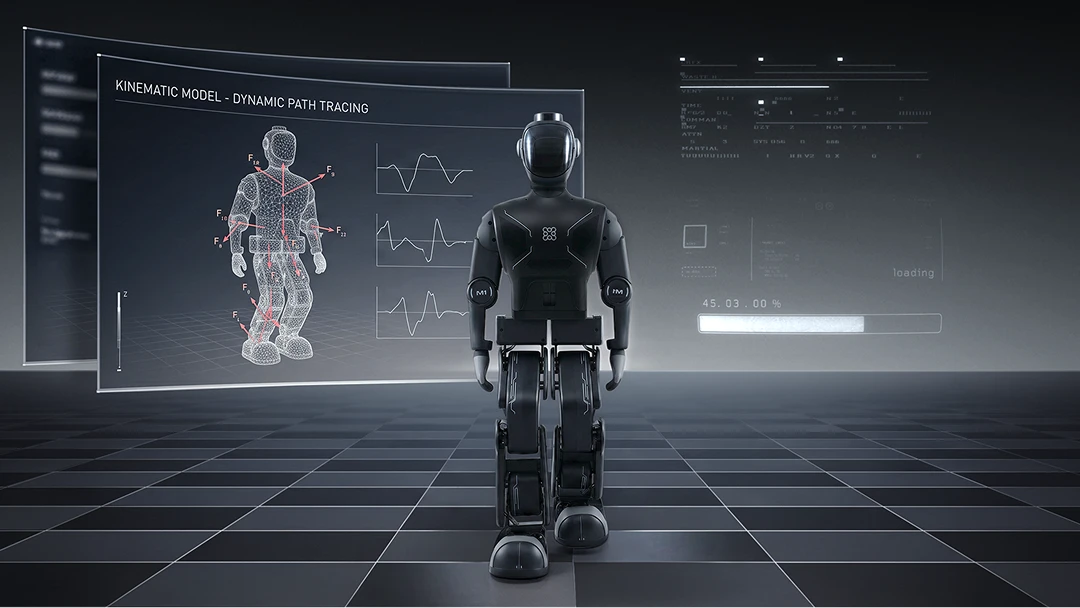
Open SDK with full-stack control
Gain direct access at every layer with the Python SDK or the M1 Spine SDK for low-latency control. Designed for ROS 2 integration and Linux + OTA workflows.
03
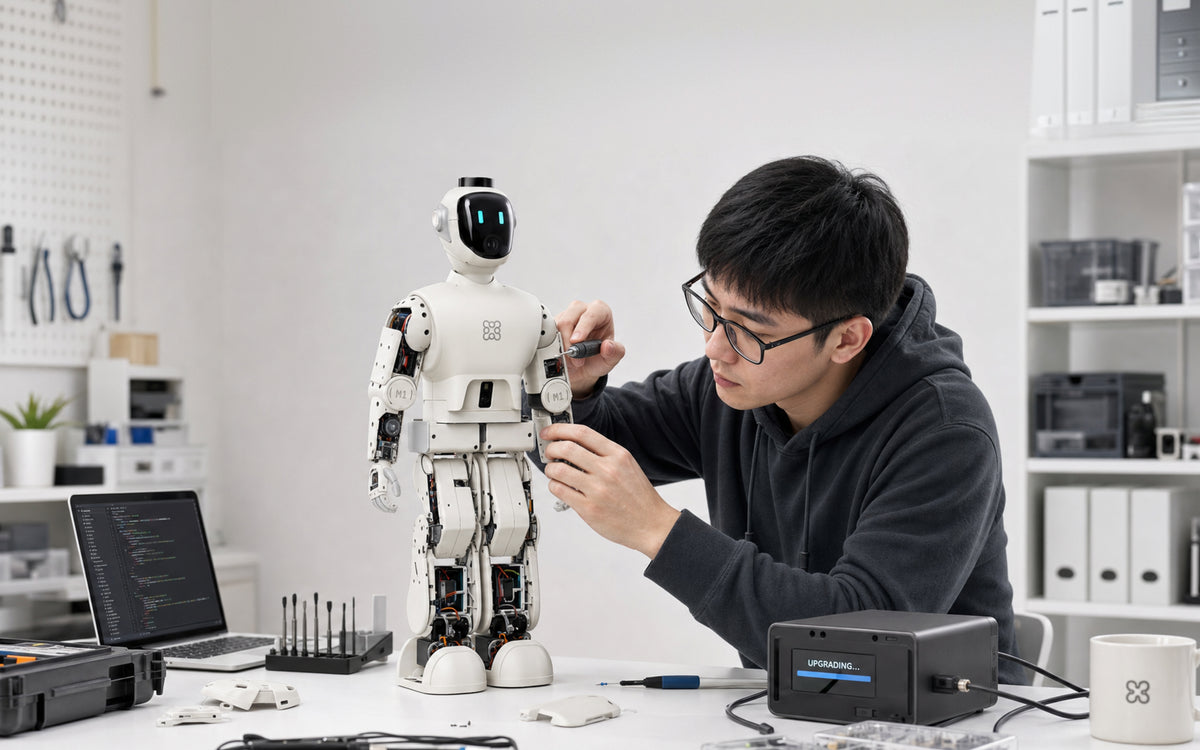
On-device Visual Perception
On-device Visual Perception equipped with stereo cameras for high-precision on-device visual perception. Supports on-device SLAM, obstacle negotiation, and visual spatial reasoning with no cloud latency required.
04
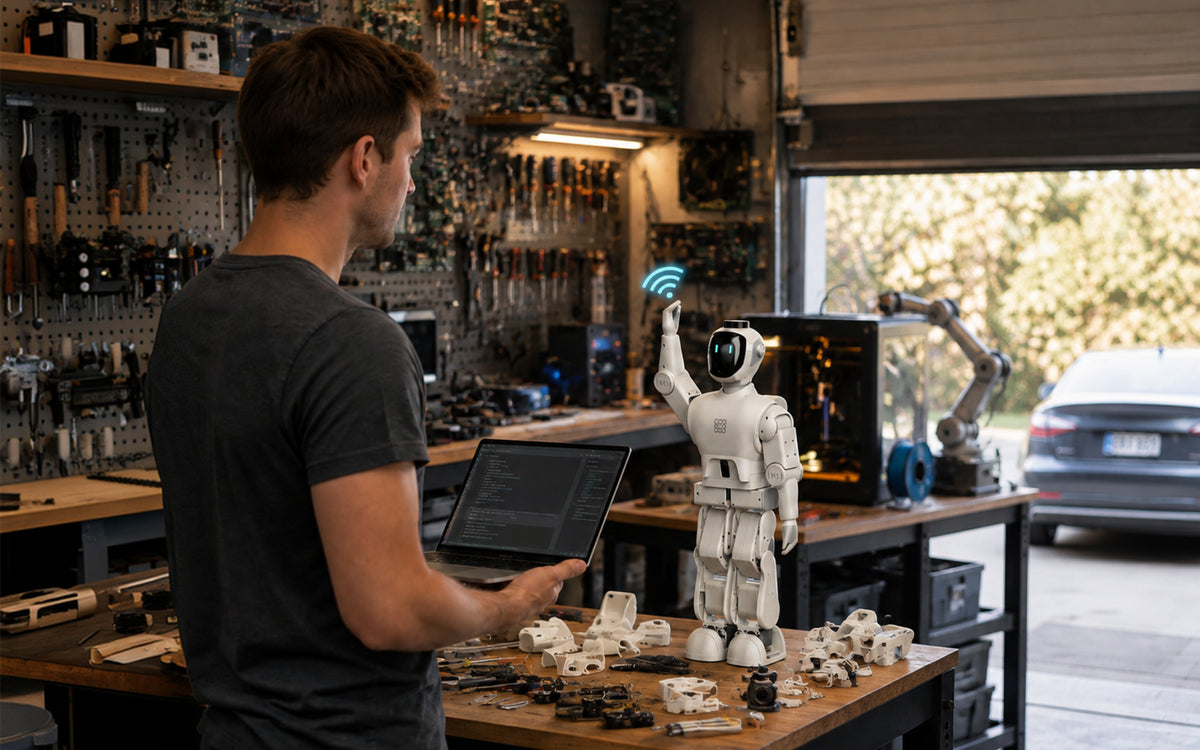
10 TOPS NPU (BPU) and high-frequency sensor streaming
Execute neural network inference locally on the 10 TOPS NPU (BPU). Stream motor torque, thermal states, 6-axis IMU data, and bus metrics into your training logs or ROS 2 environment.
05
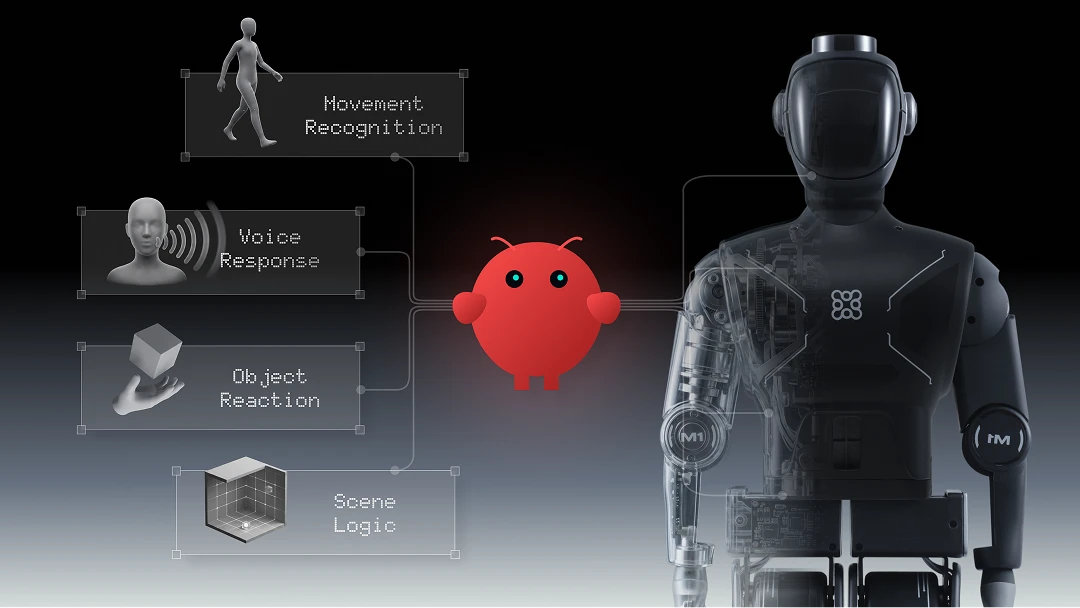
20-DoF high-torque actuator array
Actuators engineered for dynamic balance, low inertia, and high impact recovery. Designed to withstand real-world trial-and-error policy testing.
06
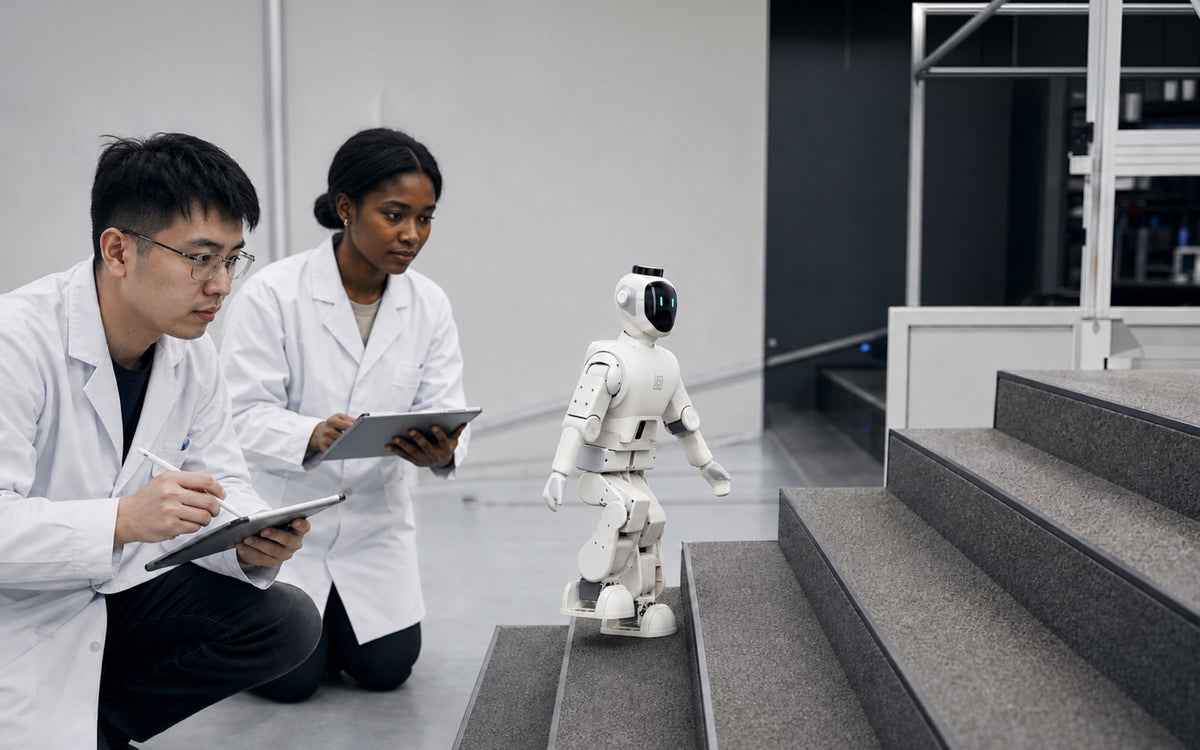
Versatile bipedal and wheeled form factor
A compact 50 cm, 2.7 kg (≈ 6 lb) desktop humanoid. Transitions between bipedal and wheeled modes to support diverse control policies in tight spaces.
05 / TECHNICAL SPECIFICATIONS
COMPACT BODY.
SERIOUS CAPABILITY.
Wheeled mode: 0.6 m/s
Wheeled: 0.79 inches
iTOF depth: detects small household obstacles
Vision camera: recognition & avoidance
IMU: posture and motion tracking
Natural, continuous conversation
ABS · rubber · silicone · glass


Zeroth Micro Robot On-Site Demo


06 / FAQ
Q&A
SECTION
The essentials, answered clearly.
Yes — full refund any time before dispatch.
Yes — US, EU, UK, Canada, Australia, Japan, and Singapore at launch. Import duties may apply.
Four regions — EU (27 countries + UK), North America (US + Canada), South America (Brazil, Mexico, Chile, Colombia, Peru, and other major LatAm countries), and Rest of World (Oceania, China-Japan-Korea, Southeast Asia, South Asia, Middle East, Central Asia, Africa, Hong Kong/Macau/Taiwan).
12 months standard in most markets. Extended to 36 months in Spain, Portugal, Sweden (EU), and Quebec, Canada (effective October 2026).
Yes. M1 provides reference workflows designed specifically for Isaac Gym. Policies trained in PyTorch can be easily exported via ONNX and deployed to the physical robot through the Reinforced Imitation Framework for efficient sim-to-real transfer. Example training scripts and reference policies are available directly through the private developer Discord community.
To deliver maximum flexibility for development and control, the Micro Robot SDK features a robust Python API for high-level behavioral workflows alongside the low-latency Micro Robot Spine SDK for direct motor control commands. Micro Robot is architected for seamless integration with ROS 2 environments at the message-bus level.
Yes. M1 features an integrated 10 TOPS NPU (BPU) optimized for local neural network inference, processing real-time spatial data directly from the dual binocular cameras. Developers can deploy custom models via the standard ONNX toolchain, and the Joyin engineering team is available to assist with model quantization recipes and operator optimization.
Zeorth provides dedicated support to keep your hardware operational. For any maintenance, chassis servicing, or component repair inquiries, developers can contact the Joyin support team directly for guided technical assistance and service options.
To safeguard the robot's high-torque actuators during dynamic policy testing, M1 features built-in hardware force limits by default. This ensures safe operation and long-term durability during aggressive movement, push recovery, and contact-rich reinforcement learning experiments.